← Overview · 3D gallery · GitHub
Asset library
11 assets composed into one USD stage, scan2usd_library.usda. Each asset is a payload
(loaded on demand) with two variant sets authored in the library layer, so the asset files are never edited:
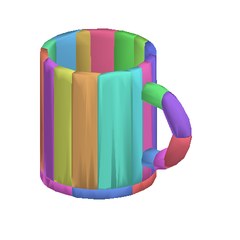
collision (decomposed · convex_hull · bounding_box) and friction (measured · low · high).
Total 8.21 kg, 345 convex colliders in the default variant.
Use it
scan2usd library output/assets -o library.usda        # build

from pxr import Usd
stage = Usd.Stage.Open("library.usda", Usd.Stage.LoadNone)   # instant: nothing loaded yet
mug = stage.GetPrimAtPath("/Library/ceramic_mug")
stage.Load(mug.GetPath())                                     # load just this asset
mug.GetVariantSet("collision").SetVariantSelection("convex_hull")
mug.GetVariantSet("friction").SetVariantSelection("low")
Why variants: the same scene can be simulated with cheap or accurate contact geometry (ablations, speed vs. fidelity),
and contact properties can be randomized for robust policies, without copying assets.
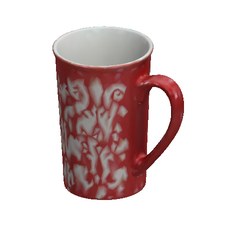
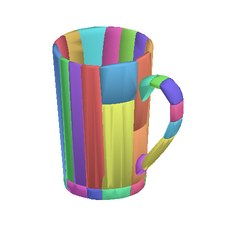
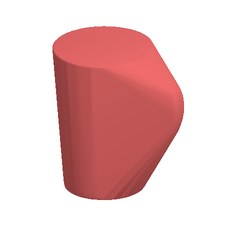
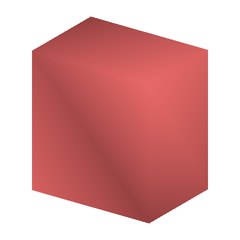
Printed mug size 12.6 × 9.1 × 13.5 cm mass 466 g inertia 689 · 1032 · 1168 g·cm² friction μs 0.60 · μd 0.50 prim /Library/ace_coffee_mug_kristen_16_oz_cup
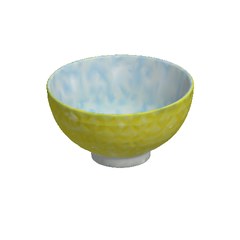
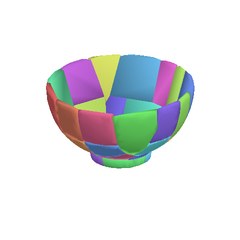
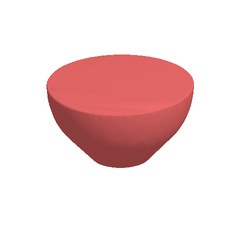
convex decomposition · 32 one convex hull · 1 bounding box · 1 Ceramic bowl size 11.3 × 11.5 × 6.2 cm mass 192 g inertia 238 · 242 · 377 g·cm² friction μs 0.60 · μd 0.50 prim /Library/cole_hardware_bowl_scirocco_yellowblue
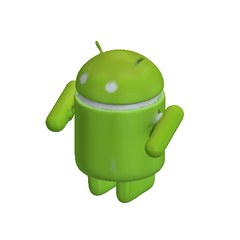
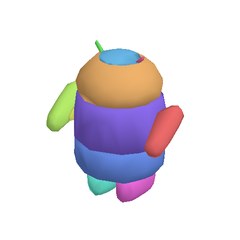
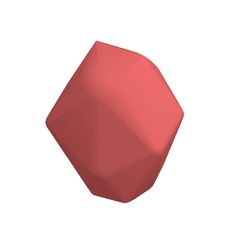
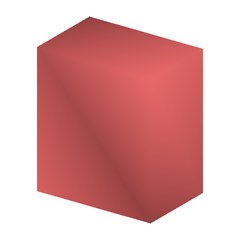
convex decomposition · 32 one convex hull · 1 bounding box · 1 Android figure size 6.9 × 4.6 × 7.9 cm mass 104 g inertia 28 · 44 · 48 g·cm² friction μs 0.40 · μd 0.30 prim /Library/great_dinos_triceratops_toy
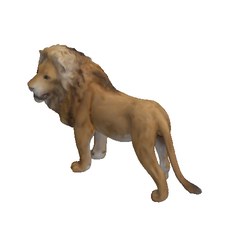
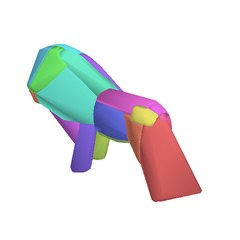
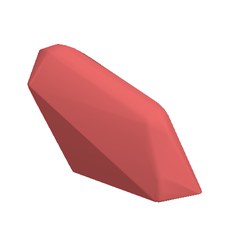
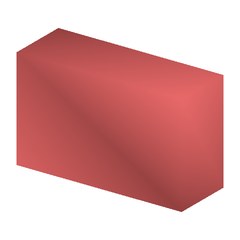
convex decomposition · 11 one convex hull · 1 bounding box · 1 Lion figure size 11.5 × 4.2 × 7.0 cm mass 55 g inertia 15 · 61 · 67 g·cm² friction μs 0.40 · μd 0.30 prim /Library/schleich_lion_action_figure
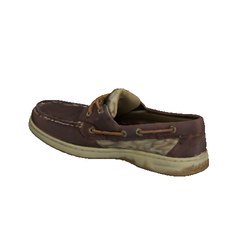
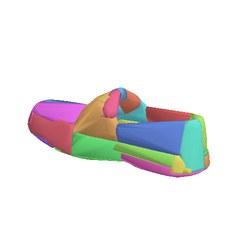
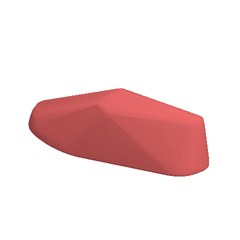
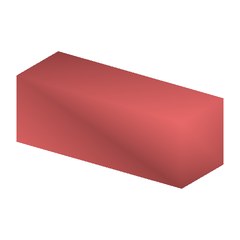
convex decomposition · 32 one convex hull · 1 bounding box · 1 Boat shoe size 24.9 × 9.0 × 9.0 cm mass 653 g inertia 515 · 2925 · 3018 g·cm² friction μs 1.00 · μd 0.80 prim /Library/womens_bluefish_2eye_boat_shoe_in_tan
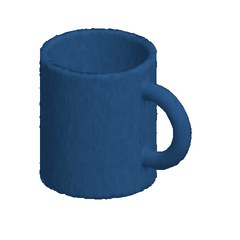
convex decomposition · 32 one convex hull · 1 bounding box · 1 Ceramic mug (synthetic scan) size 12.0 × 8.2 × 9.6 cm mass 372 g inertia 536 · 571 · 653 g·cm² friction μs 0.60 · μd 0.50 prim /Library/ceramic_mug
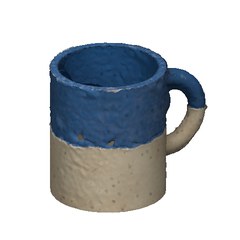
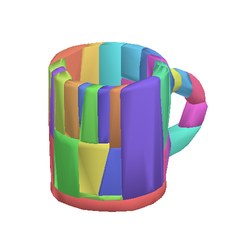
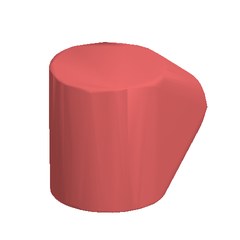
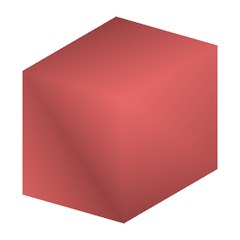
convex decomposition · 25 one convex hull · 1 bounding box · 1 Speckled mug (78 photos → USD) size 8.8 × 11.6 × 9.6 cm mass 436 g inertia 657 · 689 · 800 g·cm² friction μs 0.60 · μd 0.50 prim /Library/speckled_mug
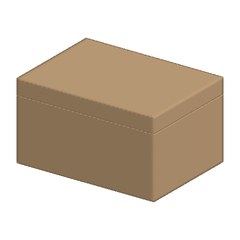
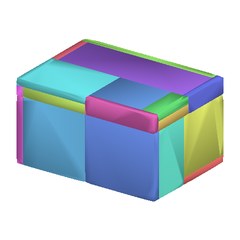
convex decomposition · 32 one convex hull · 1 bounding box · 1 Hinged box (articulated) size 18.0 × 13.0 × 10.0 cm mass 539 g inertia articulated (per body) friction μs 0.50 · μd 0.40 prim /Library/keepsake_box
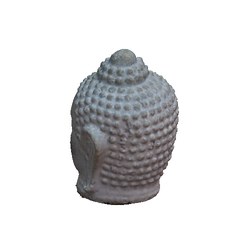
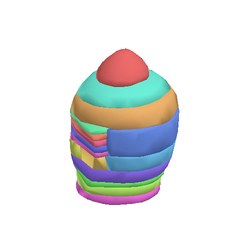
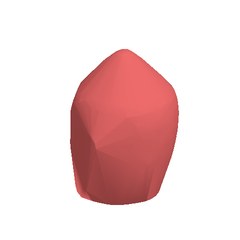
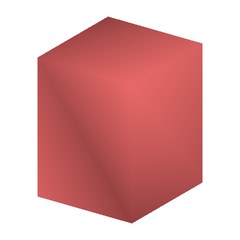
convex decomposition · 25 one convex hull · 2 bounding box · 2 Buddha head (67 real photos) size 15.2 × 16.2 × 20.0 cm mass 4624 g inertia 9024 · 13967 · 14135 g·cm² friction μs 0.70 · μd 0.60 prim /Library/buddha_head
convex decomposition · 21 one convex hull · 1 bounding box · 1 Controller holder (own phone photos) size 10.1 × 10.8 × 21.0 cm mass 528 g inertia 443 · 1920 · 1970 g·cm² friction μs 0.40 · μd 0.30 prim /Library/cod_holder
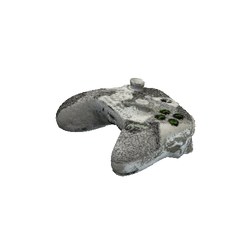
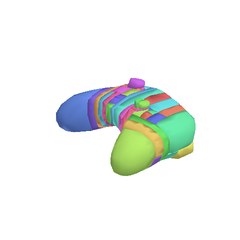
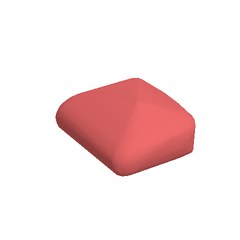
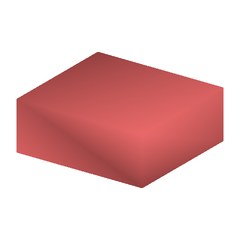
convex decomposition · 64 one convex hull · 1 bounding box · 1 Game controller (own phone photos) size 14.6 × 13.5 × 5.6 cm mass 243 g inertia 151 · 410 · 511 g·cm² friction μs 0.40 · μd 0.30 prim /Library/controller
convex decomposition · 39 one convex hull · 1 bounding box · 1 Renders: Scan2USD's numpy preview renderer. Third-party meshes: Google Scanned Objects (CC-BY 4.0); Buddha: AliceVision dataset (CC-BY 4.0).